اینورتر برای جرثقیل سقفی؛ راهنمای انتخاب درایو مناسب، تنظیم ترمز و مقاومت ترمز

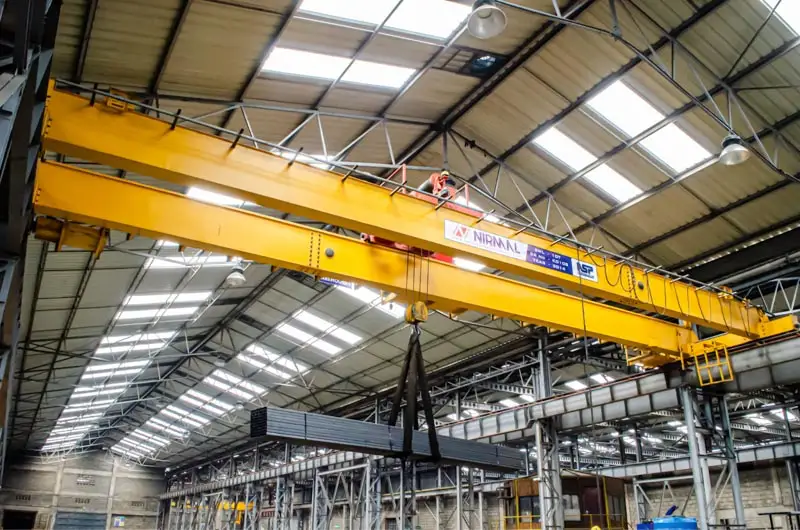
اینورتر برای جرثقیل سقفی چگونه عملکرد موتور و حرکت بار را کنترل میکند؟
اگر به دنبال اینورتر برای جرثقیل سقفی هستید، فقط عدد کیلووات موتور را ملاک قرار ندهید. در جرثقیل، جریان موتور، نوع حرکت، گشتاور موردنیاز در سرعت پایین، نحوه عملکرد ترمز مکانیکی، تعداد دفعات استارت و توقف و انرژی برگشتی بار همگی در انتخاب درایو مؤثر هستند.
نیاز موتور بالابر یا Hoist با موتور حرکت پل و کالسکه یکسان نیست. در Hoist، بار در ارتفاع قرار دارد و کنترل گشتاور و ترمز اهمیت بیشتری پیدا میکند؛ در حرکت پل و کالسکه، شروع و توقف نرم، کنترل اینرسی و کاهش ضربه اولویت بالاتری دارند.
در ادامه دقیقاً بررسی میکنیم که برای هر بخش جرثقیل چه مشخصاتی مهم است، اینورتر چگونه انتخاب میشود، مقاومت ترمز چه زمانی لازم است و در صورت بروز خطا باید چه مواردی بررسی شوند.
اینورتر جرثقیل سقفی چیست و چه کاری انجام میدهد؟
اینورتر یا درایو کنترل دور، فرکانس و ولتاژ خروجی به موتور را کنترل میکند و به این ترتیب امکان تنظیم سرعت، شتابگیری و توقف موتور را فراهم میسازد.
در یک جرثقیل سقفی این قابلیت چند مزیت مهم ایجاد میکند:
- حرکت موتور بهجای شروع ناگهانی، بهصورت نرم آغاز میشود.
- سرعت حرکت بار قابل کنترل میشود.
- توقف پل و کالسکه نرمتر انجام میشود.
- ضربه واردشده به موتور، گیربکس و مجموعه مکانیکی کاهش پیدا میکند.
- کنترل موتور در سرعتهای پایین دقیقتر میشود.
- هماهنگی بهتری بین موتور و ترمز مکانیکی ایجاد میشود.
به همین دلیل استفاده از اینورتر فقط برای تغییر سرعت نیست؛ کیفیت حرکت جرثقیل تا حد زیادی به انتخاب و تنظیم صحیح درایو وابسته است.
برای جرثقیل سقفی چه اینورتری مناسب است؟
برای انتخاب اینورتر جرثقیل سقفی، اول باید مشخص شود درایو قرار است کدام بخش را کنترل کند؛ چون نیاز بالابر، پل و کالسکه یکسان نیست.
| بخش جرثقیل | مهمترین نیاز درایو |
|---|---|
| Hoist یا بالابر | گشتاور مناسب در دور پایین، کنترل ترمز و مدیریت انرژی برگشتی |
| Bridge یا پل | شتابگیری نرم، کنترل اینرسی و توقف کنترلشده |
| Trolley یا کالسکه | کنترل سرعت، تغییر جهت نرم و توقف دقیق |
برای Hoist چه چیزی مهمتر است؟
در بخش بالابر، موتور باید زیر بار و در سرعت پایین عملکرد پایداری داشته باشد. به همین دلیل باید جریان موتور، گشتاور در دور پایین، نوع کنترل، ترمز مکانیکی، انکودر و مقاومت ترمز بررسی شوند.
برای Bridge و Trolley چه چیزی مهمتر است؟
در حرکت پل و کالسکه، مسئله اصلی معمولاً شروع و توقف نرم، کنترل اینرسی و جلوگیری از ضربههای ناگهانی است. زمان شتابگیری، کاهش سرعت و تعداد استارت و توقفها در انتخاب و تنظیم درایو اهمیت زیادی دارند.
آیا توان موتور برای انتخاب کافی است؟
خیر. توان فقط یکی از معیارهاست. جریان نامی موتور، نوع حرکت، تعداد موتورها، سیکل کاری و شرایط بار نیز باید بررسی شوند.
اگر دو موتور همزمان با یک درایو کنترل شوند، مجموع جریان آنها باید در محاسبه ظرفیت درایو لحاظ شود.
چرا نباید اینورتر جرثقیل را فقط بر اساس کیلووات انتخاب کرد؟
فرض کنید روی پلاک موتور عدد 7.5 kW نوشته شده است. این اطلاعات برای شروع انتخاب مفید است، اما برای انتخاب نهایی کافی نیست.
دو موتور 7.5 کیلووات ممکن است جریان نامی، Duty، نوع کاربری و شرایط بار متفاوتی داشته باشند.
برای انتخاب صحیح اینورتر باید حداقل این اطلاعات بررسی شوند:
- توان موتور
- جریان نامی موتور
- ولتاژ موتور
- ولتاژ شبکه
- Hoist، Bridge یا Trolley بودن موتور
- وزن و نوع بار
- تعداد دفعات حرکت در ساعت
- زمان مطلوب شتاب و توقف
- نوع ترمز مکانیکی
- وجود یا عدم وجود Encoder
- شرایط دمایی و محیط نصب
در دفترچه سری L نیز تأکید شده که درایو باید بتواند جریان موردنیاز موتور را هنگام شتابگیری تحت بار تأمین کند و جریان مجاز موتور باید با ظرفیت خروجی درایو سازگار باشد.
پس کیلووات مهمتر است یا آمپر؟
هر دو مهماند، اما بعد از مشخص شدن توان، جریان موتور یکی از مهمترین معیارهای انتخاب مدل نهایی است.
اگر درایو از نظر کیلووات ظاهراً مناسب باشد اما جریان خروجی کافی نداشته باشد، ممکن است در استارت، شتابگیری یا زیر بار با محدودیت جریان یا خطا مواجه شود.
آیا برای جرثقیل باید اینورتر را یک سایز بزرگتر انتخاب کنیم؟
این قانون که «برای جرثقیل همیشه یک رنج بالاتر انتخاب کنید» قانون دقیقی نیست.
در بعضی پروژهها شرایط بار و جریان باعث میشود مدل بزرگتر انتخاب مناسبتری باشد، اما این تصمیم باید بر اساس جریان پلاک موتور، نوع حرکت و سیکل کاری گرفته شود.
اگر جریان موتور در محدوده خروجی مدل انتخابشده قرار ندارد یا کاربری به جریان بالاتری هنگام شتابگیری نیاز دارد، باید ظرفیت بالاتر بررسی شود.
بنابراین بهجای انتخاب کورکورانه یک سایز بالاتر، مشخصات موتور را با جدول جریان خروجی درایو مقایسه کنید.
جدول انتخاب اینورتر سری L زیما برای برق سهفاز
درایوهای سهفاز سری L زیما برای کاربردهای کرین و بالابر در توانهای ۱.۵ تا ۳۰ کیلووات ارائه میشوند. برای انتخاب اولیه میتوانید توان و جریان خروجی مدلها را در جدول زیر مقایسه کنید:
| مدل درایو | توان نامی | جریان خروجی نامی |
|---|---|---|
| L100B015-3 | ۱.۵ کیلووات | ۵ آمپر |
| L100B022-3 | ۲.۲ کیلووات | ۷ آمپر |
| L100B030-3 | ۳ کیلووات | ۹ آمپر |
| L100B040-3 | ۴ کیلووات | ۱۰ آمپر |
| L100B055-3 | ۵.۵ کیلووات | ۱۳ آمپر |
| L200C075-3 | ۷.۵ کیلووات | ۱۹ آمپر |
| L200C110-3 | ۱۱ کیلووات | ۲۶ آمپر |
| L200C150-3 | ۱۵ کیلووات | ۳۶ آمپر |
| L300D185-3 | ۱۸.۵ کیلووات | ۴۰ آمپر |
| L300D220-3 | ۲۲ کیلووات | ۴۷ آمپر |
| L300D300-3 | ۳۰ کیلووات | ۶۳ آمپر |
آیا با برق تکفاز میتوان از اینورتر برای جرثقیل استفاده کرد؟
در سری L زیما، مدلهایی با ورودی تکفاز ۲۲۰ ولت و خروجی سهفاز ۲۲۰ ولت در توانهای ۱.۵، ۲.۲ و ۳ کیلووات ارائه شدهاند. بنابراین در کاربردهایی که برق سهفاز در دسترس نیست، میتوان متناسب با مشخصات موتور، مدل تکفاز مناسب را بررسی کرد.
| مدل | توان نامی | جریان خروجی |
|---|---|---|
| L100B015-1 | ۱.۵ کیلووات | ۹ آمپر |
| L100B022-1 | ۲.۲ کیلووات | ۱۱ آمپر |
| L100B030-1 | ۳ کیلووات | ۱۶.۵ آمپر |
نکته مهم این است که خروجی این مدلها سهفاز ۲۲۰ ولت است، نه ۳۸۰ ولت. بنابراین قبل از انتخاب، باید ولتاژ قابل اتصال موتور، نحوه سربندی و جریان نامی آن با خروجی درایو تطبیق داده شود.
تفاوت اینورتر بالابر با اینورتر حرکت پل چیست؟
در حرکت پل و کالسکه، مسئله اصلی معمولاً اینرسی است. یک مجموعه سنگین باید بدون ضربه شروع به حرکت کند و سپس بدون توقف ناگهانی متوقف شود.
اما در Hoist، وزن بار دائماً روی موتور اثر دارد.
زمان بالا رفتن، موتور باید بار را بلند کند. هنگام پایین آمدن نیز شرایط میتواند برعکس شود و وزن بار موتور را به حرکت درآورد.
به همین دلیل در بخش Hoist باید توجه بیشتری به موارد زیر داشت:
- گشتاور موتور در سرعت پایین
- عملکرد صحیح ترمز مکانیکی
- نحوه آزاد شدن ترمز
- نحوه بسته شدن ترمز
- کنترل سرعت پایین
- انرژی برگشتی
- مقاومت ترمز
- در صورت نیاز فیدبک انکودر
چرا گشتاور در دور پایین برای جرثقیل مهم است؟
فرض کنید بار از حالت توقف قرار است بالا برود.
در همان لحظات اولیه، سرعت موتور پایین است؛ اما موتور باید گشتاور کافی برای کنترل و حرکت دادن بار داشته باشد.
اگر کنترل موتور در این ناحیه ضعیف باشد، حرکت ممکن است با لرزش، تأخیر یا رفتار نامطلوب همراه شود.
به همین دلیل هنگام انتخاب اینورتر برای جرثقیل سقفی فقط حداکثر سرعت اهمیت ندارد؛ رفتار موتور در چند لحظه ابتدایی حرکت بسیار مهم است.
در مشخصات سری L زیما، گشتاور راهاندازی تا 150 درصد گشتاور نامی در 0.5 هرتز ذکر شده و دقت کنترل گشتاور نیز در مشخصات فنی این سری تعریف شده است.
Vector Control در جرثقیل چه کاربردی دارد؟
در کنترل Vector، درایو میتواند رفتار گشتاوری موتور را دقیقتر مدیریت کند.
این قابلیت در کاربردهایی که موتور باید در دور پایین تحت بار کار کند اهمیت بیشتری پیدا میکند.
برای حرکت ساده پل ممکن است نیازهای کنترلی متفاوت باشد، اما برای Hoist کنترل مناسب گشتاور در سرعت پایین میتواند نقش تعیینکنندهای داشته باشد.
سری L زیما از Sensorless Vector Control و Closed Loop Vector Control پشتیبانی میکند.
Open Loop بهتر است یا Closed Loop؟
هیچ پاسخ یکسانی برای تمام جرثقیلها وجود ندارد.
چه زمانی Open Loop مناسب است؟
در Open Loop، کنترل موتور بدون دریافت فیدبک مستقیم سرعت از انکودر انجام میشود.
برای بسیاری از حرکتهای معمولی پل و کالسکه و بعضی کاربردهای بالابری، در صورت انتخاب و تنظیم صحیح، Open Loop میتواند پاسخگوی نیاز سیستم باشد.
Closed Loop چه زمانی بررسی میشود؟
وقتی نیاز به کنترل دقیقتر سرعت و گشتاور وجود داشته باشد، استفاده از انکودر و Closed Loop میتواند مفید باشد.
برای مثال:
- حرکتهای بسیار آرام
- نیاز به کنترل دقیقتر سرعت
- کاربریهای حساستر
- نیاز به فیدبک واقعی از موتور
سری L زیما قابلیت کار با موتور القایی بدون انکودر و همچنین موتورهای دارای انکودر را دارد و برای حالتهای Closed Loop نیز کارتهای PG متناسب با نوع انکودر در نظر گرفته شدهاند.
آیا هر جرثقیل سقفی به انکودر نیاز دارد؟
خیر.
این تصور که چون کاربرد جرثقیل است حتماً باید از انکودر استفاده شود، صحیح نیست.
نوع محور، دقت موردنیاز و نحوه کنترل موتور تعیین میکند که Encoder لازم است یا خیر.
در حرکتهای سادهتر معمولاً Open Loop گزینه قابل بررسی است. هرچه نیاز به کنترل دقیقتر موتور در سرعت پایین بیشتر شود، استفاده از Closed Loop اهمیت بیشتری پیدا میکند.
اگر از انکودر استفاده کنیم، چه نکاتی مهم است؟
یکی از مشکلات رایج سیستمهای فیدبک، نویز روی سیگنال انکودر است.
طبق راهنمای سری L زیما، کابل انکودر بهتر است:
- از کابلهای قدرت فاصله داشته باشد؛
- شیلددار باشد؛
- تا حد امکان کوتاه انتخاب شود؛
- متناسب با کارت PG و نوع انکودر متصل شود.
این نکته در جرثقیل اهمیت زیادی دارد، چون موتور، درایو، کنتاکتور و کابلهای قدرت همگی میتوانند منابع نویز الکتریکی باشند.
ترمز مکانیکی جرثقیل چه ارتباطی با اینورتر دارد؟
ترمز مکانیکی و اینورتر دو تجهیز جداگانهاند اما در Hoist باید کاملاً با هم هماهنگ باشند.
قرار نیست اینورتر جای ترمز مکانیکی را بگیرد.
در شروع حرکت باید شرایطی ایجاد شود که موتور توانایی کنترل بار را داشته باشد و سپس ترمز مکانیکی آزاد شود.
در توقف نیز ابتدا حرکت باید بهصورت کنترلشده کاهش پیدا کند و ترمز در زمان مناسب درگیر شود.
ترتیب صحیح باز شدن ترمز چگونه است؟
منطق کلی کار به این صورت است:
فرمان حرکت ← آماده شدن موتور و ایجاد گشتاور ← آزاد شدن ترمز ← شروع حرکت
اگر ترمز قبل از آماده شدن موتور آزاد شود، احتمال حرکت ناخواسته بار افزایش پیدا میکند.
در سری L زیما نیز پارامترها و منطق مشخصی برای زمانبندی آزاد شدن ترمز در نظر گرفته شده است.
چرا بار در لحظه باز شدن ترمز کمی حرکت میکند؟
اگر هنگام آزاد شدن ترمز، موتور هنوز نتوانسته باشد گشتاور مناسب ایجاد کند، ممکن است حرکت کوتاهی در بار مشاهده شود.
در چنین شرایطی باید مجموعه سیستم بررسی شود، نه فقط یک پارامتر.
مواردی که باید کنترل شوند شامل این موارد هستند:
- مشخصات موتور
- نحوه تیون موتور
- حالت Open Loop یا Closed Loop
- عملکرد انکودر
- وضعیت ترمز مکانیکی
- زمانبندی فرمان ترمز
- جریان و ظرفیت درایو
تغییر تصادفی پارامترها بدون پیدا کردن علت اصلی معمولاً روش مناسبی برای رفع این مشکل نیست.
آیا اینورتر میتواند جای ترمز مکانیکی را بگیرد؟
خیر.
اینورتر وظیفه کنترل موتور را برعهده دارد و ترمز مکانیکی وظیفه مستقلی در سیستم بالابر دارد.
در طراحی Hoist باید فرض شود که در شرایط توقف، Fault یا قطع تغذیه، سیستم مکانیکی و ایمنی بتواند وظیفه موردنظر را انجام دهد.
بنابراین حذف ترمز مکانیکی صرفاً به دلیل استفاده از درایو تصمیم درستی نیست.
مقاومت ترمز اینورتر جرثقیل چیست؟
هنگام پایین آوردن یک بار سنگین، همیشه موتور صرفاً مصرفکننده انرژی نیست.
وزن بار میتواند موتور را به حرکت درآورد و در این وضعیت انرژی به سمت DC Bus درایو بازگردد.
اگر این انرژی در سیستم باقی بماند، ولتاژ باس DC افزایش پیدا میکند.
مقاومت ترمز یکی از تجهیزاتی است که امکان دفع این انرژی به شکل گرما را فراهم میکند.
سری L زیما قابلیت Dynamic Brake و اتصال مقاومت ترمز خارجی را دارد.
آیا همه جرثقیلها به مقاومت ترمز نیاز دارند؟
خیر.
میزان نیاز به مقاومت ترمز به شرایط واقعی حرکت بستگی دارد.
موارد زیر روی مقدار انرژی برگشتی تأثیر میگذارند:
- وزن بار
- سرعت حرکت
- تعداد دفعات پایین آوردن بار
- زمان کاهش سرعت
- سیکل کاری
- نوع محور
- اینرسی مکانیکی
در حرکت بالابر معمولاً موضوع انرژی برگشتی اهمیت بیشتری دارد، اما حتی در حرکتهای افقی با جرم زیاد و توقف سریع نیز ممکن است انرژی قابلتوجهی به درایو برگردد.
مقاومت ترمز جرثقیل را چگونه انتخاب کنیم؟
مقاومت ترمز دو مشخصه مهم دارد:
مقدار اهم مقاومت
مقدار مقاومت باید در محدودهای باشد که برای مدار ترمز مدل درایو مجاز است.
انتخاب اهم نامناسب میتواند جریان مدار ترمز را از محدوده طراحی خارج کند.
توان مقاومت
توان مقاومت مشخص میکند قطعه چه مقدار انرژی حرارتی را میتواند تحمل کند.
این قسمت مستقیماً به سیکل کاری مرتبط است.
یک جرثقیل که در هر ساعت چند حرکت کوتاه دارد با جرثقیلی که بهصورت مداوم بار را بالا و پایین میبرد، مقاومت ترمز یکسانی نیاز ندارد.
در جدول فنی سری L زیما، توان مقاومتهای پیشنهادی با فرض 10 درصد برگشت انرژی در نظر گرفته شده است. اگر انرژی برگشتی کاربرد بیشتر باشد، توان مقاومت باید متناسب با آن افزایش پیدا کند؛ در حالی که محدوده اهم مجاز مدل تغییر نمیکند.
این نکته یکی از مهمترین مواردی است که هنگام انتخاب مقاومت ترمز باید در نظر گرفته شود.
مقاومت ترمز سری L به کدام ترمینال متصل میشود؟
در سری L ترمینالهای B+ و B- برای اتصال مقاومت ترمز در نظر گرفته شدهاند.
مقدار اهم، توان مقاومت و سیمکشی باید متناسب با مدل دقیق درایو انتخاب شوند. نصب مدار قدرت و مقاومت ترمز نیز باید توسط فرد متخصص انجام شود، زیرا انتخاب یا اتصال نامناسب میتواند باعث آسیب به تجهیزات و ایجاد حرارت خطرناک شود.
چرا اینورتر هنگام پایین آوردن بار خطای Over Voltage میدهد؟
یکی از دلایل مهم میتواند برگشت انرژی از موتور به DC Bus باشد.
اما Over Voltage فقط یک علت ندارد.
در راهنمای سری L زیما مواردی مانند اینها برای بررسی مطرح شدهاند:
- بالا بودن ولتاژ ورودی
- نوسان برق
- شرایط نامناسب شتاب یا کاهش سرعت
- نبود یا عملکرد نامناسب مقاومت ترمز
- ناسازگار بودن مقاومت ترمز با درایو
بنابراین اگر خطای اضافهولتاژ دیده شد، تعویض فوری اینورتر یا تغییر تصادفی پارامترها راهحل مناسبی نیست؛ علت باید مرحلهبهمرحله بررسی شود.
چرا اینورتر جرثقیل هنگام استارت Over Current میدهد؟
اگر خطای اضافهجریان هنگام شتابگیری رخ دهد، چند مورد باید بررسی شود:
- شتابگیری بیش از حد سریع
- بالا بودن بار مکانیکی
- ایراد موتور
- اتصال کوتاه یا ایراد کابل موتور
- ناسازگاری جریان موتور و ظرفیت درایو
- مشکل در آزاد شدن ترمز
اگر ترمز مکانیکی کاملاً آزاد نشود، موتور برای حرکت دادن بار جریان بیشتری خواهد کشید.
راهنمای سری L نیز برای خطاهای اضافهجریان، بررسی بار، موتور، کابلها، ظرفیت درایو و وضعیت ترمز را توصیه میکند.
خطای Overload در جرثقیل معمولاً از چیست؟
Overload زمانی رخ میدهد که موتور یا درایو برای مدت مشخص تحت بار بیش از ظرفیت قرار گیرد.
مواردی که باید بررسی شوند شامل این موارد هستند:
- سنگین بودن بار
- پایین بودن ظرفیت درایو
- کار طولانی در سرعت بسیار پایین و زیر بار
- کوتاه بودن زمان شتابگیری یا توقف
- آزاد نشدن کامل ترمز
- تنظیم نادرست جریان نامی موتور
در چنین شرایطی ابتدا باید علت مکانیکی یا الکتریکی مشخص شود و صرفاً افزایش ظرفیت درایو همیشه اولین راهحل نیست.
خطای مقاومت ترمز در سری L به چه معناست؟
اگر مقدار انرژی برگشتی بیشتر از توان قابلتحمل مقاومت باشد، امکان ایجاد هشدار مربوط به اضافهبار مقاومت ترمز وجود دارد.
در راهنمای سری L، برای خطای Brake Resistor Over Load کم بودن توان مقاومت نسبت به کاربرد بهعنوان یکی از دلایل اصلی مطرح شده است.
اگر این خطا تکرار میشود، باید Duty Cycle واقعی پروژه و توان مقاومت بررسی شوند.
چرا اینورتر داخل تابلو داغ میشود؟
گرمای بیش از حد میتواند ناشی از یک یا چند عامل باشد:
- دمای زیاد محیط
- تهویه ضعیف تابلو
- خرابی فن
- بار زیاد
- آلودگی و کثیف شدن هیتسینک
- فرکانس سوئیچینگ بالا
- قرار گرفتن تجهیزات گرمازا در نزدیکی درایو
بدنه سری L دارای درجه حفاظت IP20 است؛ بنابراین محل نصب و شرایط تابلو اهمیت دارد. در راهنمای نصب نیز بر تهویه مناسب محفظه و کنترل دمای داخل تابلو تأکید شده است.
آیا اینورتر سری L را میتوان مستقیماً در محیط سوله نصب کرد؟
با توجه به IP20 بودن بدنه، باید محیط نصب از نظر گردوغبار، رطوبت، تماس مستقیم و آلودگی بررسی شود.
در محیطهای صنعتی بهتر است درایو داخل تابلو یا محفظه مناسب نصب شود و جریان هوای کافی برای خنککاری آن وجود داشته باشد.
نصب مناسب فقط برای افزایش عمر درایو نیست؛ گردوغبار و گرمای بیش از حد میتوانند باعث خطاهای مکرر و کاهش پایداری سیستم شوند.
آیا میتوان دو موتور جرثقیل را با یک اینورتر راهاندازی کرد؟
در بعضی کاربردهای حرکت پل، امکان استفاده از یک درایو برای دو موتور مشابه وجود دارد؛ اما این کار قواعد خودش را دارد.
مجموع جریان موتورها باید در انتخاب درایو لحاظ شود و موتورها باید از نظر مشخصات و جهت حرکت با سیستم طراحیشده سازگار باشند.
در یکی از مثالهای آموزشی زیما برای حرکت جرثقیل سقفی، دو موتور مشابه 2.2 کیلووات با یک درایو 5.5 کیلووات راهاندازی شدهاند و جریان نامی تنظیمشده برابر مجموع جریان دو موتور در نظر گرفته شده است. همچنین بر یکسان بودن جهت گردش موتورها تأکید شده است.
این مثال یک نمونه آموزشی است و به معنی مناسب بودن همین ترکیب برای تمام جرثقیلهای دارای دو موتور نیست.
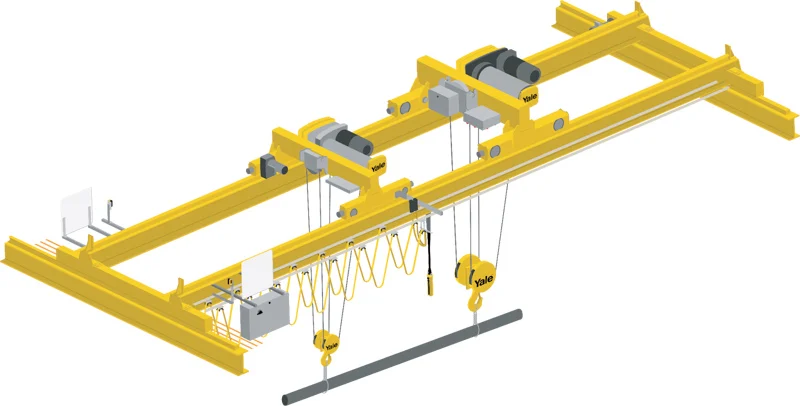
آیا میتوان جرثقیل کنتاکتوری را اینورتری کرد؟
در بسیاری از سیستمها امکان نوسازی کنترل حرکت وجود دارد.
استفاده از درایو برای حرکت طولی و عرضی میتواند حرکت را نرمتر کرده و نیاز به قطعووصل مکرر برای تغییر جهت را کاهش دهد.
در مستندات زیما نیز استفاده از درایو برای حرکت طولی و عرضی جرثقیل بهمنظور حرکت نرمتر و کاهش ضربه بررسی شده است.
اما نوسازی یک جرثقیل قدیمی صرفاً با اضافه کردن اینورتر تمام نمیشود. وضعیت موتور، ترمز، تجهیزات حفاظتی، تابلو، فرمانها و سیمکشی نیز باید بررسی شوند.
آیا میتوان کنتاکتور خروجی موتور را هنگام کار اینورتر قطع کرد؟
قطع و وصل ناگهانی اتصال موتور در زمانی که درایو در حال اعمال جریان است میتواند باعث ایجاد خطا و رفتار نامناسب شود.
در راهنمای سری L نیز برای برخی خطاهای افت جریان تأکید شده که کنتاکتور موتور نباید هنگامی که جریان روی خروجی درایو وجود دارد، بیدلیل قطع و وصل شود.
منطق فرمان کنتاکتور باید با وضعیت Enable و فرمانهای درایو هماهنگ باشد.
آیا اینورتر باعث کاهش نوسان بار جرثقیل میشود؟
استارت و توقف نرم میتواند از ایجاد ضربه شدید و بخشی از نوسانات ناشی از تغییر سرعت ناگهانی جلوگیری کند.
اما صرف وجود اینورتر به این معنی نیست که سیستم بهطور خودکار هر نوع نوسان بار را حذف میکند.
تنظیم صحیح شتاب، کاهش سرعت و رفتار اپراتور همچنان اهمیت زیادی دارند.
آیا اینورتر جرثقیل باعث کاهش مصرف برق میشود؟
درایو به موتور اجازه میدهد متناسب با نیاز واقعی سیستم کار کند و جریان راهاندازی و نحوه حرکت موتور را کنترل میکند.
این موضوع میتواند در برخی سیکلهای کاری باعث بهبود مصرف انرژی شود، اما نباید برای تمام جرثقیلها یک درصد ثابت صرفهجویی اعلام کرد.
در کاربرد جرثقیل، مزیت اصلی درایو بیشتر در کنترل بهتر موتور، حرکت نرم، تنظیم سرعت و کاهش ضربههای مکانیکی دیده میشود.
اگر برق قطع شود، آیا اینورتر میتواند بار را نگه دارد؟
نباید نگه داشتن ایمن بار را فقط به عملکرد اینورتر وابسته کرد.
در سیستم Hoist، ترمز مکانیکی و مدار ایمنی باید مستقل از کنترل عادی موتور در نظر گرفته شوند.
اینورتر بخشی از سیستم کنترل حرکت است؛ نه جایگزین تمام اجزای ایمنی مکانیکی جرثقیل.
بهترین اینورتر برای جرثقیل سقفی چه ویژگیهایی باید داشته باشد؟
بهجای اینکه فقط دنبال یک توان یا نام مدل باشید، این موارد را بررسی کنید:
- جریان خروجی متناسب با موتور
- کنترل مناسب گشتاور در سرعت پایین
- ظرفیت Overload مناسب
- امکان تنظیم شتاب و کاهش سرعت
- قابلیت کنترل Open Loop و در صورت نیاز Closed Loop
- امکان اتصال انکودر
- پشتیبانی از مقاومت ترمز
- قابلیت هماهنگی با منطق ترمز
- حفاظت اضافهجریان و اضافهبار
- امکان تنظیم و تیون دقیق موتور
- پشتیبانی فنی و مستندات راهاندازی
اینورترهای سری L زیما با تمرکز بر کاربردهای کرین و بالابر، قابلیتهایی مانند کنترل برداری، Open Loop و Closed Loop، Autotune، الگوریتم Learning موتور، کنترل گشتاور در سرعت پایین و Dynamic Brake را در اختیار کاربر قرار میدهد.
قبل از خرید اینورتر جرثقیل چه اطلاعاتی آماده کنیم؟
اگر میخواهید انتخاب مدل دقیق باشد، قبل از استعلام این اطلاعات را آماده کنید:
- عکس پلاک موتور
- توان موتور
- جریان نامی موتور
- ولتاژ موتور
- نوع برق ورودی
- مشخص کردن Hoist، Bridge یا Trolley
- ظرفیت جرثقیل
- وضعیت ترمز مکانیکی
- تعداد تقریبی حرکت در ساعت
- وجود یا عدم وجود انکودر
- زمان موردنظر برای شتابگیری و توقف
- شرایط محیط نصب و تابلو
این اطلاعات بسیار ارزشمندتر از جمله ساده «برای موتور 7.5 کیلووات چه اینورتری بخرم؟» هستند.
هنگام انتخاب اینورتر جرثقیل سقفی چه اشتباهاتی را انجام ندهیم؟
فقط بر اساس کیلووات خرید نکنید
جریان موتور و شرایط بار را هم بررسی کنید.
مقاومت ترمز را حدسی انتخاب نکنید
محدوده اهم و توان باید با مدل درایو و میزان انرژی برگشتی سازگار باشد.
تنظیمات یک جرثقیل دیگر را کپی نکنید
حتی دو جرثقیل با موتور همتوان ممکن است گیربکس، بار، ترمز و سیکل کاری متفاوت داشته باشند.
کابل انکودر را کنار کابل قدرت عبور ندهید
در سیستم Closed Loop، نویز میتواند کیفیت فیدبک انکودر را مختل کند.
تهویه تابلو را نادیده نگیرید
گرمای بیش از حد میتواند باعث خطا و کاهش عمر تجهیزات شود.
مشکل مکانیکی را با تغییر پارامتر اینورتر پنهان نکنید
ترمز گیرکرده، مکانیزم سفت، بار بیش از حد یا موتور معیوب با تنظیم نرمافزاری واقعاً تعمیر نمیشوند.
جمعبندی؛ کدام اینورتر برای جرثقیل سقفی مناسب است؟
انتخاب اینورتر برای جرثقیل سقفی از پلاک موتور شروع میشود، اما به آن ختم نمیشود.
اگر اینورتر برای Hoist استفاده میشود، کنترل گشتاور در سرعت پایین، عملکرد ترمز و انرژی برگشتی اهمیت بیشتری دارند. برای حرکت پل و کالسکه نیز شتابگیری نرم، توقف کنترلشده و ظرفیت مناسب جریان از عوامل مهم هستند.
در سری L زیما مدلهای مختلفی از 1.5 تا 30 کیلووات برای کاربردهای کرین و بالابر ارائه شدهاند و انتخاب مدل باید بر اساس جریان موتور، نوع محور و شرایط واقعی کار انجام شود.
اگر بین دو مدل مردد هستید، بهجای حدس زدن، عکس پلاک موتور، نوع حرکت جرثقیل، ظرفیت بار و شرایط کاری دستگاه را در اختیار کارشناسان فنی زیما قرار دهید تا درایو و مقاومت ترمز متناسب با پروژه بررسی شود.
برای مشاهده آموزشهای عملی درباره تنظیم اینورتر، پارامترها، راهاندازی موتور و نکات کاربردی درایو به بخش آموزش ویدئویی اینورترهای زیما مراجعه کنید.
سوالات متداول درباره اینورتر جرثقیل سقفی
در این بخش به پرتکرارترین سوالات درباره انتخاب اینورترهای بالابر، توان و جریان مناسب، مقاومت ترمز، انکودر، خطاهای رایج و تنظیمات مهم درایو پاسخ میدهیم تا قبل از خرید یا راهاندازی، دید دقیقتری نسبت به نیاز سیستم داشته باشید.
آیا هر اینورتری برای جرثقیل مناسب است؟
خیر. جریان خروجی، کنترل گشتاور، شرایط اضافهبار، نوع کنترل و امکان مدیریت ترمز باید با کاربری جرثقیل سازگار باشند.
آیا اینورتر جرثقیل باید یک سایز بزرگتر از موتور باشد؟
نه الزاماً. مدل باید بر اساس جریان واقعی موتور و شرایط بار انتخاب شود.
آیا برای Hoist به مقاومت ترمز نیاز داریم؟
در بسیاری از کاربریهای Hoist انرژی هنگام پایین آمدن بار به سمت درایو بازمیگردد و مقاومت ترمز باید بررسی شود؛ اما انتخاب آن وابسته به شرایط واقعی پروژه است.
آیا انکودر برای جرثقیل الزامی است؟
خیر. بسته به دقت و نوع کاربرد میتوان از Open Loop یا Closed Loop استفاده کرد.
علت Over Voltage هنگام پایین آمدن بار چیست؟
انرژی برگشتی، ولتاژ ورودی بالا، تنظیم نامناسب شتاب و توقف یا مشکل در سیستم مقاومت ترمز از مواردی هستند که باید بررسی شوند.
علت Over Current هنگام شروع حرکت چیست؟
شتاب زیاد، بار سنگین، آزاد نشدن ترمز، ایراد موتور یا کابل و پایین بودن ظرفیت جریان درایو از موارد قابل بررسی هستند.
آیا میتوان دو موتور پل را به یک درایو متصل کرد؟
در بعضی پروژهها امکانپذیر است، اما مجموع جریان، مشابه بودن موتورها و شرایط طراحی باید بررسی شوند.
برای انتخاب اینورتر، توان مهمتر است یا جریان؟
هر دو مهم هستند، اما جریان پلاک موتور و جریان خروجی درایو باید حتماً با یکدیگر تطبیق داده شوند.
آیا سری L زیما برای جرثقیل طراحی شده است؟
بله. این خانواده برای کاربردهای کرین و بالابر طراحی شده و قابلیتهایی مانند کنترل گشتاور در سرعت پایین، Open Loop، Closed Loop، اتصال انکودر و مقاومت ترمز را ارائه میکند.
برای انتخاب دقیق مدل چه اطلاعاتی لازم است؟
عکس پلاک موتور، توان، جریان، ولتاژ، نوع حرکت، ظرفیت بار، تعداد سیکل کاری، وضعیت ترمز و وجود یا عدم وجود انکودر مهمترین اطلاعات اولیه هستند.
How Does an Overhead Crane Inverter Control the Motor and Load Movement?
When selecting an inverter for an overhead crane, motor power in kilowatts should not be the only factor considered. Motor rated current, type of motion, low-speed torque requirements, mechanical brake operation, start-stop frequency, and regenerative energy all affect proper drive selection.
The requirements of a hoist motor are different from those of bridge and trolley motors. In a hoist, the load is suspended vertically, so torque control and brake coordination become more critical. For bridge and trolley travel, smooth acceleration, controlled deceleration, inertia management, and reduced mechanical shock are usually the main priorities.
This guide explains what matters when selecting an overhead crane inverter, how the requirements differ between the hoist, bridge, and trolley, when a braking resistor may be required, and what should be checked when common drive faults occur.
What Is an Overhead Crane Inverter and What Does It Do?
An inverter controls the frequency and voltage supplied to the electric motor. This allows the drive to regulate motor speed, acceleration, and deceleration.
In an overhead crane, this provides several practical benefits:
- Smoother motor starting instead of abrupt acceleration
- Adjustable load travel speed
- Smoother bridge and trolley stopping
- Reduced mechanical shock on the motor, gearbox, and crane structure
- Better motor control at low speeds
- Better coordination between the motor and mechanical brake
For this reason, an inverter in a crane system is not used only for speed control. The quality of crane movement depends heavily on correct drive selection and proper parameter settings.
What Type of Inverter Is Suitable for an Overhead Crane?
The first step is to determine which crane motion the drive will control. The requirements of the hoist, bridge, and trolley are not the same.
| Crane Section | Main Drive Requirements |
|---|---|
| Hoist | Stable low-speed torque, brake control, and regenerative energy management |
| Bridge | Smooth acceleration, inertia control, and controlled stopping |
| Trolley | Smooth speed control, controlled direction changes, and accurate stopping |
What Matters Most for a Hoist?
A hoist motor must operate reliably while carrying a load, including at low speeds. Therefore, the following factors should be checked:
- Motor rated current
- Low-speed torque requirements
- Motor control mode
- Mechanical brake operation
- Encoder requirements
- Braking resistor requirements
What Matters Most for Bridge and Trolley Travel?
For bridge and trolley movement, the main concerns are usually smooth starting and stopping, inertia control, and avoiding sudden mechanical shock.
Acceleration time, deceleration time, number of starts and stops, direction changes, and actual motor current should all be considered when selecting and setting up the drive.
Is Motor Power Alone Enough to Select the Inverter?
No.
Motor power is only one selection criterion. Motor rated current, type of crane motion, number of motors, duty cycle, and load conditions must also be considered.
If two motors are operated simultaneously by one drive, the combined motor current must be included when sizing the inverter.
Why Shouldn’t an Overhead Crane Inverter Be Selected by Kilowatts Alone?
Suppose the motor nameplate shows 7.5 kW. This is useful information, but it is not enough for final drive selection.
Two 7.5 kW motors can have different rated currents, duty cycles, applications, and load conditions.
At minimum, the following information should be checked:
- Motor power
- Motor rated current
- Motor voltage
- Supply voltage
- Whether the motor operates the hoist, bridge, or trolley
- Load weight and operating conditions
- Number of operating cycles per hour
- Required acceleration and deceleration times
- Mechanical brake type
- Presence or absence of an encoder
- Ambient temperature and installation conditions
The drive must be able to supply the current required by the motor during acceleration under load, and the motor current must remain within the permissible output-current range of the inverter.
Which Is More Important: Kilowatts or Amps?
Both are important, but after motor power has been identified, motor rated current becomes one of the most important criteria for choosing the final inverter model.
A drive may appear suitable based on its kW rating but still be undersized if its output-current capacity is lower than the motor requires during starting, acceleration, or loaded operation.
Should You Always Select an Inverter One Size Larger for a Crane?
No.
The common rule that a crane always requires an inverter one size larger than the motor is not universally correct.
In some applications, motor current, load conditions, or duty cycle may justify selecting a larger drive. However, this decision should be based on actual operating data rather than a general rule.
If the motor rated current exceeds the output-current capacity of the selected drive, or the application requires higher current during acceleration, a higher-capacity model should be evaluated.
The correct approach is to compare the motor nameplate data with the drive’s rated output current instead of automatically oversizing the inverter.
XIMA L-Series Three-Phase Inverter Selection Table
XIMA L-Series three-phase drives for crane and lifting applications are available from 1.5 kW to 30 kW.
The following table can be used for initial model selection:
| Drive Model | Rated Power | Rated Output Current |
|---|---|---|
| L100B015-3 | 1.5 kW | 5 A |
| L100B022-3 | 2.2 kW | 7 A |
| L100B030-3 | 3 kW | 9 A |
| L100B040-3 | 4 kW | 10 A |
| L100B055-3 | 5.5 kW | 13 A |
| L200C075-3 | 7.5 kW | 19 A |
| L200C110-3 | 11 kW | 26 A |
| L200C150-3 | 15 kW | 36 A |
| L300D185-3 | 18.5 kW | 40 A |
| L300D220-3 | 22 kW | 47 A |
| L300D300-3 | 30 kW | 63 A |
This table is useful for initial comparison, but final drive selection must still be based on actual motor current and crane operating conditions.
Can an Overhead Crane Inverter Operate from a Single-Phase Supply?
Yes, for compatible motor ratings.
The L Series includes models with a 220 V single-phase input and 220 V three-phase output in 1.5, 2.2, and 3 kW ratings.
| Drive Model | Rated Power | Rated Output Current |
|---|---|---|
| L100B015-1 | 1.5 kW | 9 A |
| L100B022-1 | 2.2 kW | 11 A |
| L100B030-1 | 3 kW | 16.5 A |
The important point is that these models provide a three-phase 220 V output, not 380 V.
Motor voltage, winding configuration, and rated current must therefore be compatible with the inverter output before installation.
What Is the Difference Between a Hoist Inverter and a Bridge Travel Inverter?
The main difference is the nature of the load.
For bridge and trolley travel, the primary issue is usually inertia. A heavy moving structure must accelerate smoothly and stop in a controlled manner.
A hoist operates under different conditions because gravity continuously acts on the suspended load.
During lifting, the motor must generate enough torque to raise the load. During lowering, the load may drive the motor instead, causing energy to flow back toward the drive.
For this reason, hoist applications require greater attention to:
- Low-speed motor torque
- Mechanical brake operation
- Brake release timing
- Brake engagement timing
- Low-speed control
- Regenerative energy
- Braking resistor requirements
- Encoder feedback where required
Why Is Low-Speed Torque Important in Crane Applications?
Consider a suspended load that must begin moving upward from a standstill.
At the beginning of movement, motor speed is very low, but the motor must still generate enough torque to control and lift the load.
If motor control is weak in this operating region, the movement may become unstable, delayed, or jerky.
For this reason, maximum motor speed is not the only consideration when selecting an overhead crane inverter. Motor behavior during the first moments of movement is equally important.
For the L Series, the specified starting torque is up to 150% of rated torque at 0.5 Hz.
What Is Vector Control Used for in an Overhead Crane?
Vector control allows the drive to manage motor torque more precisely.
This becomes especially important when the motor must operate under load at low speed.
Bridge travel may have different control requirements, but in hoisting applications, stable low-speed torque can play an important role in smooth load movement.
The L Series supports both Sensorless Vector Control and Closed-Loop Vector Control.
Open-Loop or Closed-Loop Control: Which Is Better?
There is no single answer for every crane.
When Is Open-Loop Control Suitable?
In open-loop operation, the drive controls the motor without receiving direct speed feedback from an encoder.
For many standard bridge and trolley applications, and some hoist applications, correctly configured open-loop control can provide the required performance.
When Should Closed-Loop Control Be Considered?
Closed-loop control uses encoder feedback and may be useful when the application requires:
- Very low-speed movement
- More precise speed control
- More demanding operating conditions
- Direct motor-speed feedback
The L Series supports induction motors without encoder feedback as well as motors using encoder feedback. PG cards are also available for closed-loop applications depending on the encoder type.
Does Every Overhead Crane Need an Encoder?
No.
An encoder is not automatically required simply because the application is an overhead crane.
The need for encoder feedback depends on the crane axis, required accuracy, motor-control method, and low-speed performance requirements.
Open-loop operation may be suitable for less demanding applications. As the required level of low-speed control and feedback accuracy increases, closed-loop operation becomes more relevant.
What Should Be Considered When Using an Encoder?
Electrical noise is one of the common issues that can affect encoder-feedback systems.
For proper encoder wiring:
- Keep encoder cables away from power cables.
- Use shielded cable.
- Keep the encoder cable as short as practical.
- Match the encoder type with the correct PG card and wiring configuration.
These precautions are especially important in crane control panels, where motors, inverters, contactors, and power cables may all generate electrical interference.
How Does the Mechanical Brake Work with the Inverter?
The inverter and mechanical brake perform different functions, but in a hoist they must operate in coordination.
The inverter does not replace the mechanical brake.
During starting, the motor must first be capable of controlling the load before the mechanical brake is released.
During stopping, motor speed should first be reduced in a controlled manner before the brake engages at the appropriate point.
What Is the Correct Brake Release Sequence?
The general operating sequence is:
Run command → Motor develops torque → Brake releases → Load begins moving
If the brake releases before the motor is ready to generate sufficient torque, unintended load movement may occur.
The L Series includes parameters and control logic for brake-release timing.
Why Does the Load Move Slightly When the Brake Releases?
If the motor has not developed sufficient torque when the mechanical brake releases, the load may move briefly.
When this happens, the entire motor-drive-brake system should be checked rather than changing a single parameter.
Items to inspect include:
- Motor data
- Motor tuning
- Open-loop or closed-loop operating mode
- Encoder operation
- Mechanical brake condition
- Brake command timing
- Drive current capacity
Changing parameters randomly without identifying the actual cause is not a reliable troubleshooting method.
Can an Inverter Replace the Mechanical Brake?
No.
The inverter controls the motor, while the mechanical brake performs a separate function in the hoisting system.
The hoist should be designed so that its mechanical and safety systems can perform their required functions during stopping, drive faults, or loss of power.
Removing the mechanical brake simply because an inverter is installed is not an appropriate design approach.
What Is a Braking Resistor in an Overhead Crane Inverter System?
When a heavy load is lowered, the motor does not always operate only as an energy consumer.
The suspended load can drive the motor, causing energy to flow back into the drive’s DC bus.
If this energy is not properly managed, DC-bus voltage can rise.
A braking resistor allows this electrical energy to be dissipated as heat.
The L Series supports dynamic braking and the connection of an external braking resistor.
Does Every Overhead Crane Need a Braking Resistor?
No.
The need for a braking resistor depends on the actual operating conditions.
Factors affecting regenerative energy include:
- Load weight
- Travel or lowering speed
- Number of lowering cycles
- Deceleration time
- Duty cycle
- Crane axis
- Mechanical inertia
Regenerative energy is particularly important in hoisting applications, although heavy horizontal movements with rapid deceleration may also return significant energy to the drive.
How Do You Select a Braking Resistor for a Crane?
Two main specifications must be considered.
Braking Resistor Resistance
The resistance value must remain within the permitted range of the drive’s braking circuit.
Using an inappropriate resistance value can cause braking-circuit current to exceed its design limits.
Braking Resistor Power Rating
The resistor power rating determines how much thermal energy the component can safely dissipate.
This is directly related to operating duty.
A crane that performs only a few short movements per hour does not have the same braking-resistor requirements as a crane that continuously raises and lowers loads.
In the L-Series technical table, the recommended resistor power values are based on 10% regenerative energy. If an application produces more regenerative energy, the resistor power rating must be increased accordingly, while the permissible resistance range for that drive model remains unchanged.
Where Is the Braking Resistor Connected on the L Series?
On the L Series, the braking resistor is connected to terminals B+ and B-.
The resistance value, power rating, and wiring method must be selected according to the exact drive model.
Incorrect resistor selection or wiring can damage the equipment and generate excessive heat, so power-circuit and braking-resistor installation should be performed by qualified personnel.
Why Does the Inverter Trip on Over Voltage While Lowering a Load?
One possible cause is regenerative energy returning from the motor to the DC bus.
However, regeneration is not the only possible cause of an Over Voltage fault.
Items to check include:
- Excessive input voltage
- Supply-voltage fluctuations
- Incorrect acceleration or deceleration settings
- Missing or improperly functioning braking resistor
- Incorrect braking-resistor selection
If an Over Voltage fault occurs, replacing the drive or changing random parameters is not an appropriate first step. The actual cause of the DC-bus voltage rise should be identified systematically.
Why Does a Crane Inverter Trip on Over Current During Starting?
If an Over Current fault occurs during acceleration, the following conditions should be checked:
- Acceleration time is too short
- Mechanical load is too high
- Motor fault
- Motor cable fault or short circuit
- Drive current capacity does not match the motor
- Mechanical brake is not fully releasing
If the brake remains partially engaged, the motor will require more current to move the load.
What Causes an Overload Fault in a Crane?
An overload condition occurs when the motor or drive operates above its permitted loading level for a specified period.
Possible causes include:
- Excessive mechanical load
- Undersized drive
- Extended low-speed operation under heavy load
- Acceleration or deceleration time that is too short
- Mechanical brake not fully releasing
- Incorrect motor rated-current setting
The mechanical and electrical causes should be identified before simply increasing the drive size.
What Does a Braking Resistor Overload Fault Mean?
If the amount of regenerative energy exceeds the resistor’s thermal capacity, a Brake Resistor Over Load warning may occur.
If this fault repeats, the actual crane duty cycle and braking-resistor power rating should be reviewed.
Why Does the Inverter Overheat Inside the Control Panel?
Excessive drive temperature may result from one or more of the following:
- High ambient temperature
- Poor panel ventilation
- Cooling-fan failure
- Excessive load
- Dirty heat sink
- High switching frequency
- Heat-producing equipment installed too close to the drive
The L-Series enclosure is rated IP20, so installation location and panel conditions are important.
Adequate ventilation and temperature control help prevent repeated thermal faults and improve system reliability.
Can an L-Series Drive Be Installed Directly in the Workshop?
Because the enclosure is IP20, the installation environment must be evaluated for dust, moisture, contamination, and accidental contact.
In industrial environments, the drive should be installed in a suitable control panel or enclosure with sufficient airflow for cooling.
Proper installation is important not only for drive life. Excessive heat and contamination can also cause repeated faults and unstable operation.
Can Two Crane Motors Be Operated from One Inverter?
In some bridge-travel applications, one inverter can operate two similar motors, but the system must be designed correctly.
The combined motor current must be considered when sizing the drive, and the motors must be compatible in terms of their specifications and required direction of rotation.
One application example uses two similar 2.2 kW motors with a 5.5 kW drive, with the configured motor rated current set to the combined current of both motors. The example also specifies that the motors must rotate in the same required direction.
This is an application example, not a fixed sizing rule for every two-motor crane system.
Can an Older Contactor-Controlled Crane Be Converted to Inverter Control?
In many systems, the motion-control system can be modernized.
Using an inverter for bridge and trolley movement can provide smoother motion and reduce repeated switching for direction changes.
However, upgrading an older crane is not simply a matter of adding a drive. The following should also be inspected:
- Motor condition
- Mechanical brake
- Protective devices
- Control panel
- Command circuit
- Wiring
The entire control and mechanical system should be evaluated before conversion.
Can the Motor Output Contactor Be Opened While the Inverter Is Running?
Suddenly disconnecting the motor while the drive is supplying output current can cause faults or abnormal operation.
The motor contactor should therefore be coordinated with the drive’s Enable and command logic rather than being switched unnecessarily while current is present at the inverter output.
Can an Inverter Reduce Crane Load Sway?
Smooth acceleration and deceleration can reduce mechanical shock and some of the load movement caused by abrupt speed changes.
However, simply installing an inverter does not mean that all load sway will automatically be eliminated.
Correct acceleration settings, deceleration settings, crane speed, and operator behavior still affect load stability.
Does an Overhead Crane Inverter Reduce Energy Consumption?
A drive allows the motor to operate according to the actual motion requirements and provides control over starting current, speed, acceleration, and deceleration.
This may improve energy use in certain duty cycles, but a fixed percentage of energy savings should not be assumed for every crane.
In crane applications, the main benefits of an inverter are generally better motor control, smoother motion, adjustable speed, and reduced mechanical shock.
Can the Inverter Hold the Load if Power Is Lost?
Safe load holding should not depend only on the inverter.
In a hoist system, the mechanical brake and safety circuit must be considered independently from normal motor control.
The inverter is one part of the crane motion-control system; it is not a replacement for the mechanical safety components used to secure the suspended load.
What Features Should a Good Overhead Crane Inverter Have?
Instead of choosing a drive only by power rating or model name, check whether it provides the capabilities required by the application:
- Output current suitable for the motor
- Stable low-speed torque control
- Appropriate overload capacity
- Adjustable acceleration and deceleration
- Open-loop control and, where required, closed-loop control
- Encoder support where required
- Braking-resistor support
- Brake-control coordination
- Overcurrent and overload protection
- Motor tuning capability
- Technical documentation and support
For crane and lifting applications, the drive should be selected according to actual motor and load requirements rather than by nominal motor power alone.
What Information Should You Prepare Before Selecting an Overhead Crane Inverter?
For accurate drive selection, prepare the following information:
- A clear photo of the motor nameplate
- Motor power
- Motor rated current
- Motor voltage
- Available supply voltage
- Whether the motor operates the hoist, bridge, or trolley
- Crane capacity
- Mechanical brake condition
- Approximate number of operating cycles per hour
- Whether an encoder is installed
- Required acceleration and stopping time
- Control-panel and installation conditions
This information is much more useful than simply asking, “Which inverter should I use for a 7.5 kW motor?”
Common Mistakes When Selecting an Overhead Crane Inverter
Selecting the Drive Only by Kilowatts
Motor current and actual load conditions must also be checked.
Choosing the Braking Resistor by Guesswork
The resistance range and power rating must match the drive model and the amount of regenerative energy.
Copying Parameters from Another Crane
Even two cranes with motors of the same rated power can have different gearboxes, loads, brakes, and duty cycles.
Routing the Encoder Cable Next to Power Cables
In closed-loop systems, electrical noise can affect the encoder feedback signal.
Ignoring Control-Panel Ventilation
Excessive temperature can cause faults and reduce equipment life.
Trying to Hide Mechanical Problems with Drive Parameters
A dragging brake, jammed mechanism, excessive load, or faulty motor cannot be properly repaired by changing software parameters.
Which Inverter Is Suitable for an Overhead Crane?
Selecting an inverter for an overhead crane starts with the motor nameplate, but it does not end there.
For a hoist, low-speed torque, brake operation, and regenerative energy are particularly important. For bridge and trolley travel, smooth acceleration, controlled stopping, and adequate current capacity are key factors.
The L Series includes models from 1.5 kW to 30 kW for crane and lifting applications, but the final model should always be selected according to motor current, crane axis, and actual operating conditions.
If there is uncertainty between two models, the motor nameplate, crane motion, load capacity, brake arrangement, and operating duty should be reviewed before selecting the drive and braking resistor.
For practical setup guidance, parameter configuration, motor commissioning, and drive-related training, users can also refer to the XIMA inverter training videos.
Frequently Asked Questions About Overhead Crane Inverters
The following answers cover common questions about overhead crane drive selection, motor current, braking resistors, encoders, common faults, and important setup considerations.
Is Every Inverter Suitable for an Overhead Crane?
No. Output-current capacity, low-speed torque control, overload capability, motor-control method, and braking requirements must match the crane application.
Should a Crane Inverter Always Be One Size Larger Than the Motor?
Not necessarily. The drive should be selected according to actual motor current and load conditions.
Does a Hoist Need a Braking Resistor?
In many hoist applications, energy can return to the drive while the load is being lowered. A braking resistor should therefore be evaluated according to the actual operating conditions.
Is an Encoder Required for an Overhead Crane?
No. Depending on the required accuracy and operating conditions, either open-loop or closed-loop control may be suitable.
What Causes an Over Voltage Fault While Lowering a Load?
Possible causes include regenerative energy, excessive input voltage, unsuitable acceleration or deceleration settings, or a problem with the braking-resistor system.
What Causes an Over Current Fault During Starting?
Possible causes include excessive acceleration, heavy mechanical load, a brake that does not fully release, motor or cable faults, or insufficient drive current capacity.
Can Two Bridge Motors Be Connected to One Drive?
In some applications, yes. However, combined motor current, motor similarity, rotation direction, protection, and system design must all be checked.
Which Is More Important When Selecting an Inverter: Motor Power or Current?
Both matter, but the motor nameplate current must always be compared with the rated output current of the selected drive.
Is the L Series Designed for Crane Applications?
Yes. The series is intended for crane and lifting applications and supports features such as low-speed torque control, open-loop and closed-loop operation, encoder connection, and braking-resistor connection.
What Information Is Needed for Accurate Drive Selection?
The most useful information includes:
- Motor nameplate
- Motor power
- Rated current
- Motor voltage
- Crane motion type
- Load capacity
- Duty cycle
- Brake arrangement
- Encoder availability
These details allow the drive and braking system to be selected according to the actual crane rather than by motor power alone.
محصولات
اینورتر 15 کیلووات سه فاز سری بالابر و جرثقیل
اینورتر 11 کیلووات سه فاز سری بالابر و جرثقیل
اینورتر 7.5 کیلووات سه فاز سری بالابر و جرثقیل
اینورتر 5.5 کیلووات سه فاز سری بالابر و جرثقیل
اینورتر 4 کیلووات سه فاز سری بالابر و جرثقیل
اینورتر 3 کیلووات سه فاز سری بالابر و جرثقیل
اینورتر 2.2 کیلووات سه فاز سری بالابر و جرثقیل
اینورتر 1.5 کیلووات سه فاز سری بالابر و جرثقیل
اینورتر 3 کیلووات تک فاز سری بالابر و جرثقیل
اینورتر 2.2 کیلووات تک فاز سری بالابر و جرثقیل
نظرات کاربران
دیدگاهها
هنوز دیدگاهی ثبت نشده است.